
 Underwater ROV
BlueROV2 The World's Most Popular Open-Source ROV

BlueROV2 - three-quarter view
A professional-grade underwater ROV engineered for real-world inspection, research, and exploration. Six T200 thrusters, 1080p low-light camera, BlueOS software, and an open accessory ecosystem - from €4,606.
Every part, and why it's there
Nothing on this vehicle is a sealed black box - each component is a part you can buy, service and replace on your own bench. Hover or tap a number to trace it to the hardware.
- 01LightingYou chooseLumen Subsea Light1,500 lumens each on a 135° beam, dimmable. Two give 3,000 lumens, four give 6,000.
- 02TrimMachined buoyancy foamTrimmed slightly positive, so a power failure floats the vehicle back to you. 1.2–1.4 kg payload capacity.
- 03StructureModular HDPE frameCorrosion-proof and drilled for payloads, with the enclosures left open on the bench. 457 × 338 × 254 mm overall.
- 04Imaging1080p low-light camera0.01 lux minimum and a 110° field of view, on a ±90° servo tilt behind the dome.
- 05PropulsionSix T200 thrusters6.7 kgf each at 20 V, in a vectored layout for full six-degree-of-freedom control. 9 kgf forward.
- 06PowerNot in the kitBattery enclosure14.8 V 18 Ah pack, 266 Wh: roughly 2 h of normal flying. Dangerous goods, shipped from our EU stock within 48 h.
The 4K Cam turns the BlueROV2 you already own
into a 4K inspection platform.
Blue Robotics’ new piloting camera is a straight retrofit for the standard 1080p USB camera - a Sony IMX678 sensor at 3840 × 2160, motorised zoom and focus, an integrated tilt servo, and 0.001 lux low-light sensitivity. It keeps piloting latency at 225 ms in 4K, so the picture gets four times sharper without the feed going soft or laggy.

The 4K Cam fitted behind the standard BlueROV2 dome - same enclosure, same dome, four times the pixels. Source: Blue Robotics
Build Your BlueROV2 Package
Select your options below. All prices are in EUR - we will confirm exact pricing including delivery anywhere in the world.

Your Configuration
Indicative EUR pricing · Click any selection to remove it
We ship to Europe and worldwide. Batteries are held in EU stock and dispatched within 48 hours. Your quote confirms exact pricing, delivery timeline, and any applicable import duties.
The 18 Ah batteries are the hard part.
We ship them with the ROV.
The BlueROV2 does not include a power source, and the 14.8 V 18 Ah Li-ion pack it runs on is the single item most likely to hold up an order. At 266 Wh it sits far above the 100 Wh air-freight threshold, so it can never move as ordinary cargo: on its own it ships as UN3480 Class 9 dangerous goods, and packed together with the vehicle as UN3481. Either way it needs certified packaging, a shipper’s declaration, trained personnel and a carrier willing to take it.
That is the part you cannot improvise - a lithium pack is never simply put in a box and sent, which is exactly why it is worth buying it from someone who is set up for it. We hold the genuine Blue Robotics packs in EU stock, dispatch them within 48 hours, and ship them with the vehicle under UN3481 as a certified dangerous-goods shipper - one order, one delivery, charger included, and no separate lithium consignment left for you to arrange.
Built to remove the limits of subsea work
Commercial-grade underwater work used to mean six-figure ROVs, dive teams or chartered vessels. The BlueROV2 was built to take those limits off the table.
01Cost barrier
Traditional inspection-class ROVs run well into six figures. The BlueROV2 delivers professional capability from a fraction of that - and you only buy the modules you need.
02Risk to divers
Currents, confined spaces, contaminated water and depth all put divers at risk. The BlueROV2 keeps people topside while the robot does the work.
03Vendor lock-in
Closed systems trap you on one vendor's roadmap. BlueOS and ArduSub are fully open-source - inspect, extend and integrate without permission.
04Rigid hardware
Most ROVs ship as a fixed package. The open frame, WetLink penetrators and PWM/Ethernet payload bus let you add sonar, grippers and sensors yourself.
Engineered for repeated salt-water deployment
Every component is designed, tested and rated for professional use in the ocean - not adapted from consumer hardware.

Vectored thrust in six degrees of freedom
The BlueROV2 runs on the Blue Robotics T200 - the world's most popular ROV thruster. Six are arranged in a vectored configuration so the vehicle pitches, rolls, yaws and translates in any direction, holding a stable attitude for clean inspection footage even in moving water.
- Flooded brushless T200 design - 300 m depth rated, salt-water proven
- Heavy Configuration adds 2 thrusters for payload stability and vertical force
- Basic ESC per thruster, driven by the Navigator Flight Controller

See clearly where there's almost no light
A 1080p 30fps low-light camera resolves detail down to 0.01 lux - near-total darkness at depth - across a 110° field of view, on a ±90° servo tilt so you can look up at a hull or down at the seabed without re-trimming the vehicle. Lighting is chosen separately: two dimmable 1,500-lumen Lumen lights give 3,000 lumens, four give 6,000.

An open frame you can actually build on
The modular HDPE frame is drilled for payloads and leaves the watertight enclosures fully accessible. Choose acrylic tubes for 100 m work or anodised aluminium for 300 m, and route any sensor through the standard WetLink Penetrator system. A Raspberry Pi 4 and Navigator Flight Controller sit inside, with a Bar30 depth sensor, IMU, magnetometers and leak detection onboard.
Extend Your BlueROV2
The BlueROV2's open architecture is purpose-built for integration. Cerulean Sonar - which we also distribute - makes the most compatible accessories for the BlueROV2 platform.

Omniscan 450 FS - Imaging Sonar
Forward-looking sonar for ROV navigation in turbid water. Mount on the BlueROV2 frame using purpose-designed brackets. 120m range, 120° horizontal FOV, real-time SonarView display via BlueOS.
View on Cerulean Sonar page →
ROV Locator - Subsea Positioning
Know exactly where your BlueROV2 is underwater. The ROV Locator series provides real-time position on a map - from the affordable ROV Locator A1 to the full Omnitrack USBL. Native BlueOS integration.
View on Cerulean Sonar page →
Tracker 650 DVL - Station Keeping
Doppler Velocity Log for precision station holding and dead-reckoning navigation. Mount to the BlueROV2 underside for hover stability in currents - ideal for inspection and survey work.
View on Cerulean Sonar page →Grippers, Sensors & More

Newton Subsea Gripper
A single-function open/close gripper rated to 300m. Mounts to the BlueROV2 frame. Controlled via a PWM output from the Navigator Flight Controller.

Newton Sediment Sampler
Collect sediment or water samples remotely. Spring-loaded mechanism with 60 ml capacity, 300m rated. Triggerable via the BlueROV2 control system.

Bar30 Depth / Pressure Sensor
High-resolution pressure and temperature sensor - included in the BlueROV2 standard build. 300m rated, 2mm depth resolution via I²C.

Ping360 Scanning Sonar
Blue Robotics' own 360° mechanical scanning sonar. 50m range, 750 kHz, 300m rated. Native BlueOS support with full 360° sweep display - for navigation and obstacle avoidance.
Manipulation
Newton Subsea Gripper
A single-function open/close gripper rated to 300 m. It bolts to the BlueROV2 frame and is driven from one PWM output on the Navigator flight controller - the same kind of channel a light uses - so it needs no extra electronics inside the enclosure.
- 300 mdepth rated
- 1PWM channel
Tip Check you have a free PWM output before you order - lights, a tilt servo and a gripper all draw from the same 16.
Not in the kit
See all grippers & manipulators →Sampling
Newton Sediment Sampler
Collect sediment or water samples remotely. A spring-loaded 60 ml chamber, rated to 300 m, triggered from the BlueROV2 control system - so a sample is one button press with the vehicle still on station.
- 60 mlsample volume
- 300 mdepth rated
Tip This is an attachment for the Newton Gripper, not a standalone tool - budget for the gripper with it on a first order.
Not in the kit
See all sampling tools →Sensing
Bar30 Depth / Pressure Sensor
The high-resolution pressure and temperature sensor that gives the BlueROV2 its depth reading and depth-hold. Rated to 300 m with 2 mm resolution, on the I²C bus.
- 300 mdepth rated
- 2 mmresolution
Tip Every BlueROV2 already has one fitted - order this as a spare. Working shallower than 10 m? The Bar02 (BR-100891, €75) resolves to 0.16 mm on the same interface.
✓ In the kit
See all sensors →Sonar
Ping360 Scanning Sonar
Blue Robotics' own 360° mechanical scanning sonar: 50 m range at 750 kHz, rated to 300 m, with native BlueOS support and a full sweep display in the pilot view. It is how you keep your bearings when the water goes dark.
- 50 mscan range
- 750 kHzfrequency
Tip Ping360 is for navigation and obstacle avoidance. If you need image detail for inspection work, look at the Cerulean Omniscan 450 FS instead - the two are often flown together.
Not in the kit
See all sonars →Browse Blue Robotics by category
Everything that goes on, in or around the BlueROV2 - explore the full range and add what you need to a quote.
Thrusters & Motors
T200 & T500 thrusters, ESCs and Lumen lights - the propulsion behind the ROV.
Sonars & Acoustics
Ping360 scanning, Omniscan imaging and DVL - see in turbid, zero-visibility water.
Sensors & Cameras
Bar30 depth, temperature, leak detection and upgrade cameras for the ROV.
Enclosures & Buoyancy
WTE enclosures, WetLink penetrators, foam and ballast for custom payloads.
All Accessories & Parts
The complete catalogue - 100+ upgrades, spares and cables for the BlueROV2.
An open software stack, not a locked black box
BlueOS runs the vehicle, ArduSub flies it and Cockpit (or QGroundControl) puts it in your hands - every layer open-source, inspectable and extensible.


BlueOS - the vehicle's operating system
BlueOS runs on the onboard Raspberry Pi 4 and serves a browser-based control panel to any connected laptop or tablet. Manage autopilot firmware and parameters, stream and record video, monitor system health and install community extensions - no software to install on your machine.
- Browser UI - works from any laptop, tablet or phone on the tether network
- Over-the-air firmware and BlueOS updates with one click
- Extension marketplace for sonar, DVL, mapping and custom tooling
- Live system monitoring, logging and network configuration

A modern ground control station
Cockpit is the modern, widget-based GCS for daily operations - a customisable layout with the live camera feed, a heading compass, depth, voltage and telemetry on a single screen. Pre-calibrated Xbox, DualShock 4 and DualSense profiles mean you can plug in a controller and fly, and record video with a telemetry subtitle track for defensible inspection records. QGroundControl remains available for mission planning and deep parameter tuning.
ArduSub Flight Modes
Three primary modes cover every scenario - from direct manual override to depth-stabilised station keeping.
Manual Mode
Direct, unassisted thruster control. Joystick inputs map directly to thruster outputs with no autopilot correction. Full pilot authority - used when maximum responsiveness is needed.
Stabilize Mode
The autopilot holds roll and pitch level when the joystick is released. The pilot controls heading, depth, and forward motion. Smooth, stable footage without fighting water movement.
Depth Hold Mode
Locks depth using the Bar30 pressure sensor. The pilot moves the ROV horizontally while ArduSub automatically compensates for vertical forces. Ideal for horizontal transect inspection.
Full Specifications
Performance & Physical ▾
| Max Depth | 100m (acrylic enclosures) / 300m (aluminium enclosures) |
| Max Speed | 1.5 m/s (approx. 3 knots) |
| Degrees of Freedom | 6 DOF - vectored thruster arrangement |
| Forward Thrust (45°) | 9 kgf (standard 6-thruster) |
| Vertical Thrust | 7 kgf (standard) |
| Payload Capacity | 1.2–1.4 kg (positive or negative) |
| Dimensions | 457 × 338 × 254 mm |
Thrusters & Power ▾
| Thrusters | 6× T200 (standard) or 8× T200 (Heavy Configuration) |
| T200 Max Thrust | 6.7 kgf at 20V / 5.25 kgf at 16V |
| T200 Depth Rating | 300m |
| Battery | 14.8V 18Ah Lithium-Ion (XT90 connector) |
| Run Time | ~2 hours normal / ~4 hours light use |
| ESC | Basic ESC (included, one per thruster) |
Camera & Lighting ▾
| Video Resolution | 1080p 30fps |
| Minimum Illumination | 0.01 lux (low-light sensor) |
| Field of View | 110° |
| Camera Tilt | ±90° servo-driven |
| Lights (standard) | 2× Lumen Subsea Light - 1,500 lm each, dimmable |
| Lights (Heavy / optional) | 4× Lumen Subsea Light - 6,000 lm total |
Electronics & Software ▾
| Onboard Computer | Raspberry Pi 4 (2 GB) |
| Flight Controller | Navigator Flight Controller (HAT for RPi4) |
| IMU | 6-DOF IMU + dual 3-DOF magnetometers + barometer |
| Depth Sensor | Bar30 (300m / 30 bar, 2mm resolution) |
| Leak Detection | Leak sensor (Navigator board) |
| Software | BlueOS + ArduSub |
| GCS | Cockpit (recommended) / QGroundControl |
| Tether Interface | Fathom-X Board (onboard) |
Tether Options ▾
| Standard Tether | 7.6mm diameter - 25m, 50m, 100m, 200m, 300m |
| Slim Tether | 4.0mm diameter - lower drag, same lengths |
| Buoyancy | Neutral (fresh water) / slightly positive (salt water) |

Where the BlueROV2 works
Deployed by professionals and researchers across every sector that needs reliable underwater observation, inspection or intervention.
Infrastructure Inspection
Hulls, piers, pipelines, dams, intakes and harbour structures - visual and sonar inspection without dewatering or divers.
Marine Science & Research
Repeatable transects, sample collection and photogrammetry for oceanography, ecology and habitat studies.
Aquaculture
Net, mooring and stock inspection inside and around sea-cages - fast checks without sending a diver into the pen.
Search & Recovery
Locate and recover objects, vehicles or evidence in low-visibility water with sonar, lights and a gripper payload.
Environmental & Conservation
Reef surveys, water-quality monitoring and species observation with minimal disturbance to sensitive habitats.
Underwater Filming
Stable, depth-held 1080p footage with telemetry overlay for documentary, broadcast and survey deliverables.
Education & R&D
An open, hackable platform for robotics teaching, computer-vision research and autonomy development.
Offshore & Energy
Platform, mooring and subsea-structure checks - aluminium enclosures take the BlueROV2 to 300 m.
BlueROV2 datasheet & specifications
Download the official Blue Robotics BlueROV2 datasheet, or build your exact configuration above and request a complete EUR quote.
Request BlueROV2 Pricing
Select your preferred configuration and tell us about your application - we will prepare a complete EUR quote, including any Cerulean Sonar or accessory additions.
Request a Quote - BlueROV2
Select your preferred package and describe your mission requirements below.
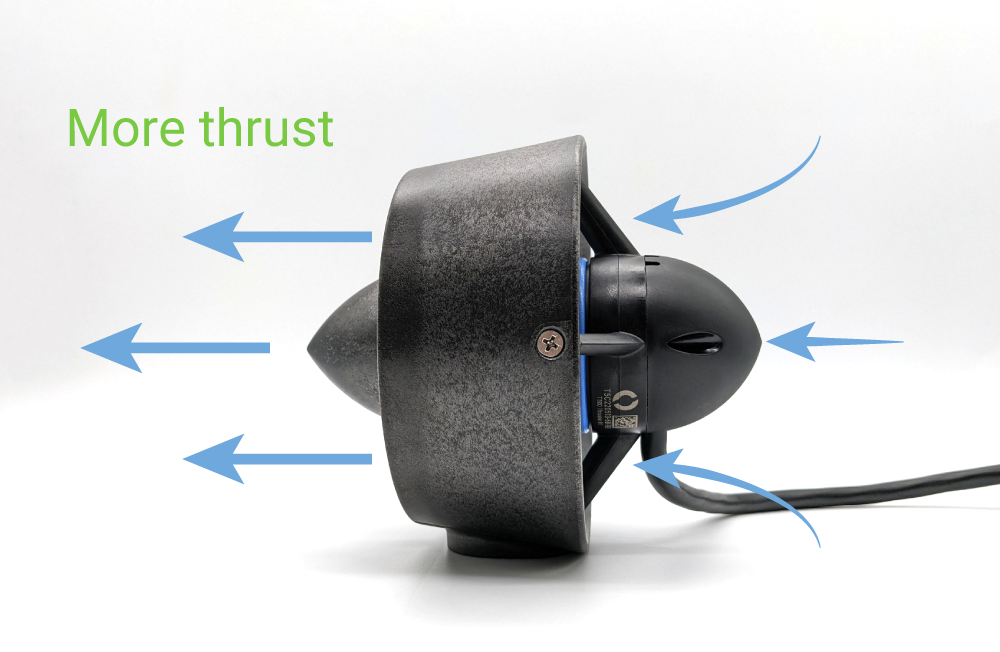


Vectored Thruster System & Heavy Kit Upgrade
The BlueROV2 is equipped with patented T200 thrusters, engineered for maximum efficiency and durability in harsh underwater environments. These thrusters deliver a high thrust-to-weight ratio and smooth, precise control, thanks to their vectored configuration. This setup allows the ROV to maneuver effortlessly in any direction, even in strong currents.
The standard BlueROV2 includes six thrusters, but for advanced missions, you can upgrade to eight with the Heavy Configuration Kit. This enhancement provides full six-degree-of-freedom movement and superior stability, making it ideal for carrying heavier payloads or operating in challenging conditions.
Performance Features:
High Thrust Output: Designed for demanding subsea operations
Corrosion-Resistant Materials: Built for long-term reliability
Adjustable Gain Settings: Fine-tune responsiveness for delicate tasks or high-power maneuvers